Robotics, Systems and Control · ETH Zürich
I make robots drive, grasp and see.
I am a Master's student at ETH Zürich working on control and learning, perception, and state estimation for robots. Before ETH, I led the driverless group of the BME Formula Racing Team.
Projects
01
High-Speed Dexterous Manipulation with the ORCAv2 Robot Hand
Reinforcement learning from simulation to a real robot hand, and a faster hand we built ourselves.
02
Relocalizing an Event Camera in a Map Built from Ordinary Images
Map a place with a normal camera in good light, then find your way in it in the dark.
03
Scalable Road Slope Mapping
Sensor fusion that maps road slope from the sensors a vehicle already has.
04
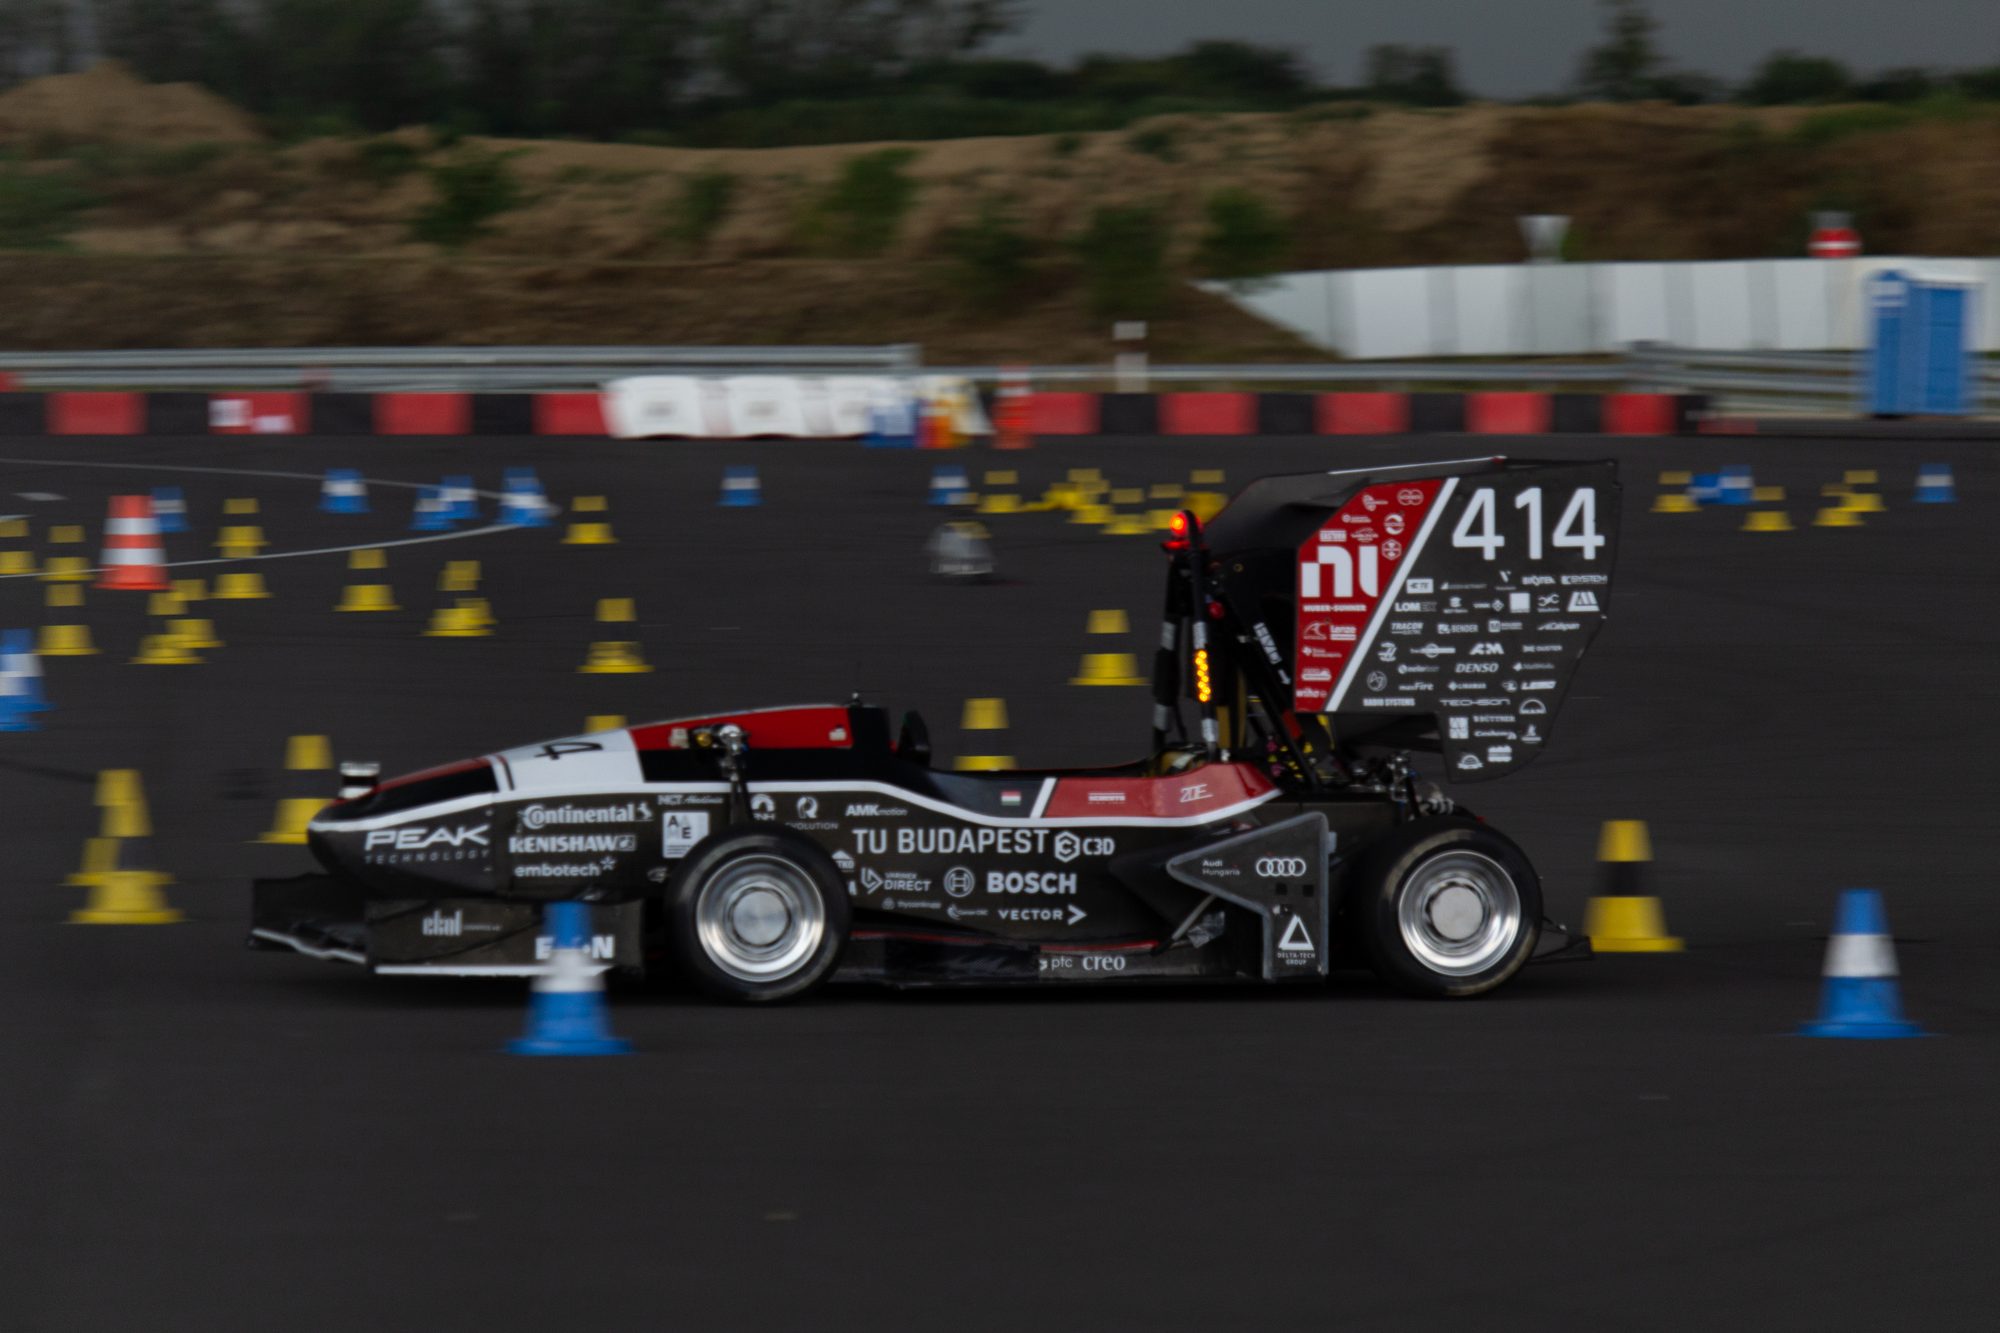
Formula Student Driverless Race Car
Control, state estimation, SLAM and perception for a self-driving race car.